Italian researchers built INSECTRON with magnetic leg connections that slip under overload and reconnect, helping a small walking prototype recover after disturbances.
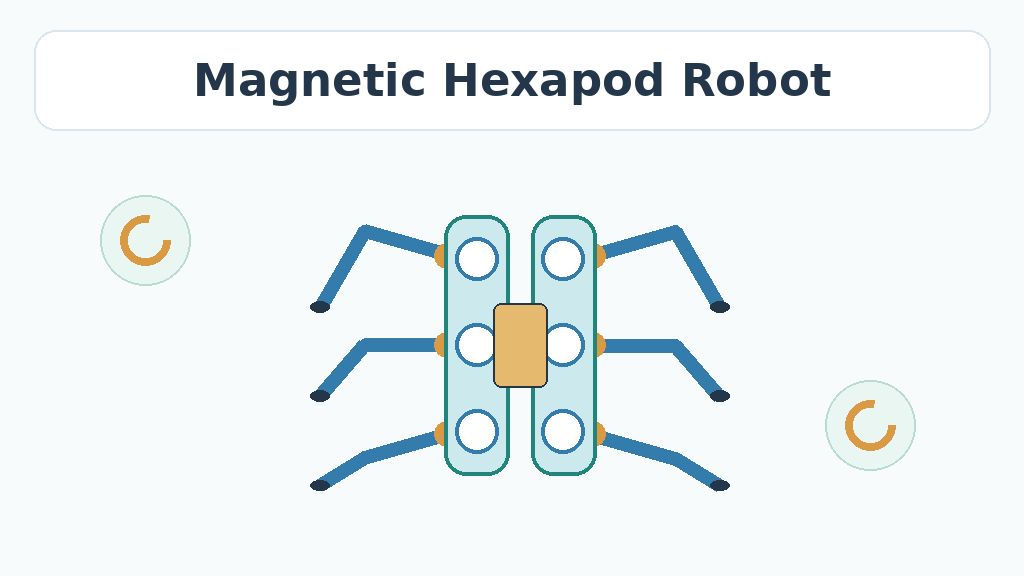
A stuck zipper needs a gentle release, not another forceful tug. Small walking robots face a similar problem when their legs catch. Even so, a magnetic hexapod robot offers a different way forward. Hexapod simply means six-legged, and this prototype goes by INSECTRON. Donato Romano and Gianluca Manduca developed it in Pisa, Italy. Both work at Sant’Anna School of Advanced Studies, within its BioRobotics Institute. In their design, magnets connect moving gears to the robot’s legs. Under excessive strain, these connections slip rather than force everything onward. As a result, the mechanism can reconnect after a disturbance ends. The researchers describe their November study in npj Robotics, published November 5, 2026. Its DOI is 10.1038/s44182-026-00106-y. For now, this is a test model, not a commercial field machine.
Why a magnetic hexapod robot needs controlled slip
Small robots must squeeze motors, gears, sensors, and batteries into cramped bodies. Meanwhile, uneven ground can catch a foot and strain its drive system. The drivetrain means the parts that carry motion from motor to leg. A rigid joint can overload gears or stall motors when something blocks movement. In other words, the motor pushes against something that will not move. Romano and Manduca wanted protection inside the drive parts themselves. Their open-access research paper describes this motivation and the resulting hardware. Instead of adding a separate motor for every leg, they used two. Each motor drives three legs through a compact set of gears. As a result, the design reduces the number of separate powered parts. However, fewer motors make reliable mechanical connections especially important. The team therefore put overload protection directly where the gears meet the legs.
Choosing the right magnetic grip
A connection that slips constantly cannot move a robot effectively. On the other hand, one that never releases may pass on a damaging knock. The team therefore had to tune the magnets’ strength, spacing, and alignment. Torque means a twisting force, like the effort used to turn a doorknob. In this case, magnetic torque carries the gear’s turning effort toward the leg. Larger magnets or smaller gaps can increase the connection’s grip. In contrast, smaller magnets or wider gaps encourage earlier release. The researchers selected a balance between normal walking and protection during overload. Even so, this balance remains a design trade-off, not an automatic guarantee. Their system also connects the left and right drive modules magnetically. As a result, those connections can accommodate brief differences in loading. The aim is useful flexibility without abandoning coordinated movement across the whole machine.
How the INSECTRON robot turns attraction into movement
The central idea starts with familiar magnetic attraction, but uses it mechanically. Neodymium magnets are strong permanent magnets made with the metal neodymium. Here, pairs of these magnets form tiny clutches at the leg connections. A clutch carries turning motion between parts and can let them separate. During ordinary walking, the magnets hold firmly enough to move each leg. If resistance rises too far, however, the connection temporarily slips. In other words, the motor does not have to fight every blockage. Once the disturbance ends, magnetic attraction brings the connection back together. The authors’ institutional research record summarizes this self-aligning arrangement. By contrast, a rigid bolt cannot yield in the same way. At the same time, magnetic joints tolerate small alignment errors during assembly. That combination makes the connection both a drive component and a safety layer.
The magnetic hexapod robot responds through its hardware
Think of a springy shoe sole cushioning a step without awaiting instructions. Similarly, this robot’s magnetic connections react through their own physical behavior. The researchers compare that response with protective mechanics found in animals. Even so, the robot does not copy an insect’s whole body or nervous system. Its passive response means the mechanism acts without a separate release command. In practice, excess load causes slipping before software needs to arrange it. Additional magnetic connections between the drive modules help absorb uneven loads. The design therefore shares protection across individual legs and the body’s drive halves. By contrast, springs can offer more direct control over stiffness. Stiffness describes how strongly something resists bending or changing shape. Magnetic connections favor simpler assembly and easy replacement over that precise control. This distinction matters when engineers choose between flexible mechanisms for different tasks.
Fig. 1: Walking Tests And Recovery In Brief
Sensors keep both sides in step
Mechanical protection does not remove the need for electronic coordination. A Hall sensor detects a magnetic field without touching the moving magnet. As magnets turn past these sensors, their signals track the gears’ positions. The controller then compares where each side sits within its movement cycle. Engineers call that position within a repeating cycle its phase. In this case, the two sides target opposite points in their cycles. At the same time, the controller adjusts one side to preserve that timing relationship. The INSECTRON robot carries its controller, battery, and sensing electronics onboard. As a result, the experiments do not require a power cable trailing behind. Wi-Fi sends measurements to a separate computer for recording and later analysis. For turns, the drive modules can run at different rates. In addition, opposing directions let the prototype spin around its body’s center.
Fig. 2: Magnetic Connections Grip, Slip, And Reconnect
What walking and disturbance tests actually show
INSECTRON measures 8.7 centimeters long, a little shorter than a ten-centimeter ruler. It weighs 33.9 grams, or roughly a third of one hundred grams. Those figures describe a compact prototype, not an industrial transport machine. On flat reference ground, its fastest tested walking reached 2.7 centimeters per second. In other words, it advanced roughly one body length every three seconds. The published experimental results also show slower progress uphill. At five degrees, speed fell to 0.8 centimeters per second. That is less than a third of the flat-ground result. Even so, the slope tests only covered gentle inclines up to five degrees. They do not establish steep climbing ability or performance across arbitrary slopes. Instead, they show how modest changes in ground angle affect this particular mechanism.
The INSECTRON robot crosses several ground surfaces
The researchers tested walking on soil, sand, perlite, and outdoor grass. Perlite consists of lightweight expanded volcanic glass, often found in gardening mixtures. Here, its loose particles created an unstable surface beneath the feet. Even so, the robot maintained forward movement across all these tested ground types. On these surfaces, the higher tested speeds approached two centimeters per second. That amounts to roughly one body length in four seconds. In addition, a separate apparatus pressed downward on the body to test recovery. The team ran 360 disturbance trials, using different press locations and holding times. Across those conditions, the robot recovered in more than ninety percent of trials. Put simply, successful recoveries exceeded nine in every ten attempts. Even then, some trials still produced unstable recovery or left the modules separated. These controlled presses do not cover every knock a robot might meet outdoors.
Energy use changes with the ground
Crossing grass required less energy per distance than crossing the tested perlite. In fact, a successful step and an economical step are not the same thing. The researchers measured electrical power and the distance traveled during each trial. They also reported cost of transport, often shortened to CoT. In plain language, it compares movement energy after accounting for weight and distance. Lower values mean less energy for the same weight and travel distance. Its name describes energy use, not a purchase price or manufacturing expense. The lowest CoT reached thirty on grass under the tested conditions. By comparison, the flat reference surface’s best reported value was forty-two. Thus, the grass result was roughly thirty percent lower on that measure. At the same time, steeper inclines reduced progress without much change in electrical power. As a result, climbing used more energy for each meter traveled.
Where easier repairs could help future research
A robot that survives strain still needs practical maintenance and further development. Here, magnetic connections allow tool-free replacement of legs without undoing tiny fasteners. That feature could help researchers change designs and resume experiments more quickly. Even so, the paper does not establish commercial readiness or document operational rescue missions. The authors discuss industrial inspection and environmental monitoring as possible future directions. Their discussion of future development also points toward terrain-adaptive feet and improved sensing. In other words, changing the feet could help match different surfaces. ENTECH’s coverage of precision-made components in robotics explores the broader importance of mechanical design. This study adds a different emphasis: some connections benefit from controlled release. Meanwhile, engineers still need to consider the limits of magnetic grip. A useful repair feature does not by itself prove long-term reliability outside research conditions.
Mechanical design meets sensing and control careers
This work sits at the meeting point of mechanics, electronics, and software. Mechanical designers shape the gears, legs, and connections that carry loads. Meanwhile, electronics engineers turn magnetic changes into signals a controller can use. Software developers then coordinate motion using that feedback instead of guesswork. In practice, the prototype shows how these specialties support the same design goal. It also offers a useful comparison with light-responsive hydrogel movement, another approach to flexible machines. However, the methods solve different problems and should not share performance claims. Students exploring robotics and STEAM education can see why material choices matter alongside coding. The study does not measure new jobs, manufacturing savings, or economic returns. In short, its direct contribution is a tested engineering approach to small walking machines. Possible business uses remain future possibilities rather than outcomes demonstrated in this paper.
Conclusion: a six-legged magnetic robot with clear limits
The six-legged magnetic robot offers a straightforward lesson about protecting moving machinery. A connection can help by yielding briefly, rather than always resisting harder. In this case, magnets carry turning effort, release under overload, and reconnect afterward. Sensors and onboard control then help preserve coordinated movement between the drive modules. This magnetic hexapod robot combines these functions within a small body for research. However, its measured speed remains only a few centimeters per second. Its gentle-slope tests and controlled presses also leave many operating conditions unexplored. In other words, promising recovery results do not establish universal toughness. The team identifies further work on sensing, feet, and changes in scale. Meanwhile, tool-free legs give researchers a practical way to modify the platform. INSECTRON demonstrates a mechanism worth studying, not a finished commercial field robot. That measured distinction keeps the engineering achievement useful without turning possibilities into promises.
References and original research
Romano, D., & Manduca, G. (2026). Insect-inspired hexapod robot with magnetically coupled compliant and modular drive system. npj Robotics, 4, Article 54. Original journal publication
The grip-and-release explanation gives readers a useful way into the mechanism. A future revision could compare the leg clutch and the body coupling more visually. The energy section could also connect its comparisons more closely with the terrain illustration. Readers seeking the experimental detail should consult the original source paper behind this article.
Editorial note
Editorial note: this is a simplified account of an engineering prototype, not an endorsement of field readiness. Please check the original research paper independently for the full methods, limitations, and evidence.
Dinesh Joshi is a leading consultant in the field of product design and development, production engineering, industrial engineering, and program management. He has worked with esteemed domestic as well as European and US organizations.
Mr. Dinesh G. Joshi has completed Graduation in Mechanical Engineering from Pune University and thereafter pursued Post Graduation in Production Engineering from Walchand College of Engineering Sangli (Shivaji University). He is member of Project Management Institute (PMI), Pennsylvania, USA as well as Indian Institute of Welding (IIW) Kolkata. He has good blend of diversified experience of about 22 years in Product Design and Development, Production Engineering, Industrial Engineering and Program Management by virtue of working in the esteemed domestic as well as European and US organizations in addition to 5 years of academic experience.